Gyros & INS
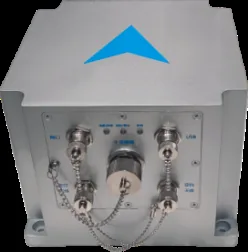
Two high-performance MEMS measurement units — gyro + accelerometer + magnetometer/barometer in compact housings, RS-422/TTL output.
Series Overview — Full Specifications
| Item | MU710 | MU730 | Evidence |
|---|---|---|---|
| Gyro measurement range | ±(125–4000) °/s | ±(300–4000) °/s | Manufacturer spec |
| Gyro bias | 0.1 °/s | 0.05 °/s | Manufacturer spec |
| Gyro bias instability (Allan) | 3 °/h | 0.4 °/h | Manufacturer spec |
| Gyro bias stability (10 s, 1σ) | 7 °/h | 3 °/h | Manufacturer spec |
| Angular random walk | 0.21 °/√h | 0.03 °/√h | Manufacturer spec |
| Accelerometer range | ±(40–200) g | ±(40–200) g | Manufacturer spec |
| Accel bias / stability | 1 mg / 0.3 mg | 1 mg / 0.3 mg | Manufacturer spec |
| Bandwidth | >120 Hz | >120 Hz | Manufacturer spec |
| Supply / current | 5 V; <0.2 A | 5 V; <0.3 A | Manufacturer spec |
| Operating temperature | −40…+90 °C | −40…+80 °C | Manufacturer spec |
| Shock tolerance | 15,000 g | 1,000 g | Manufacturer spec |
| Dimensions / weight | 25×25×9 mm; ≤30 g | 44.8×38.6×21.5 mm; ≤85 g | Manufacturer spec |
| Interfaces | RS422, TTL; baud to 460800 | RS422, TTL; baud to 460800 | Manufacturer spec |
What Is an IMU vs an INS?
An IMU (measurement unit) outputs raw angular-rate and acceleration data for your own filtering; an INS (navigation system, see M series) outputs solved position/heading/attitude. Choose IMU if you run your own estimator.
IMU or integrated navigation?
If you have your own flight software/estimator, the MU series is lighter and cheaper; if you need solved navigation output, choose the M series.
Request a Quote Request Datasheet
Product Images